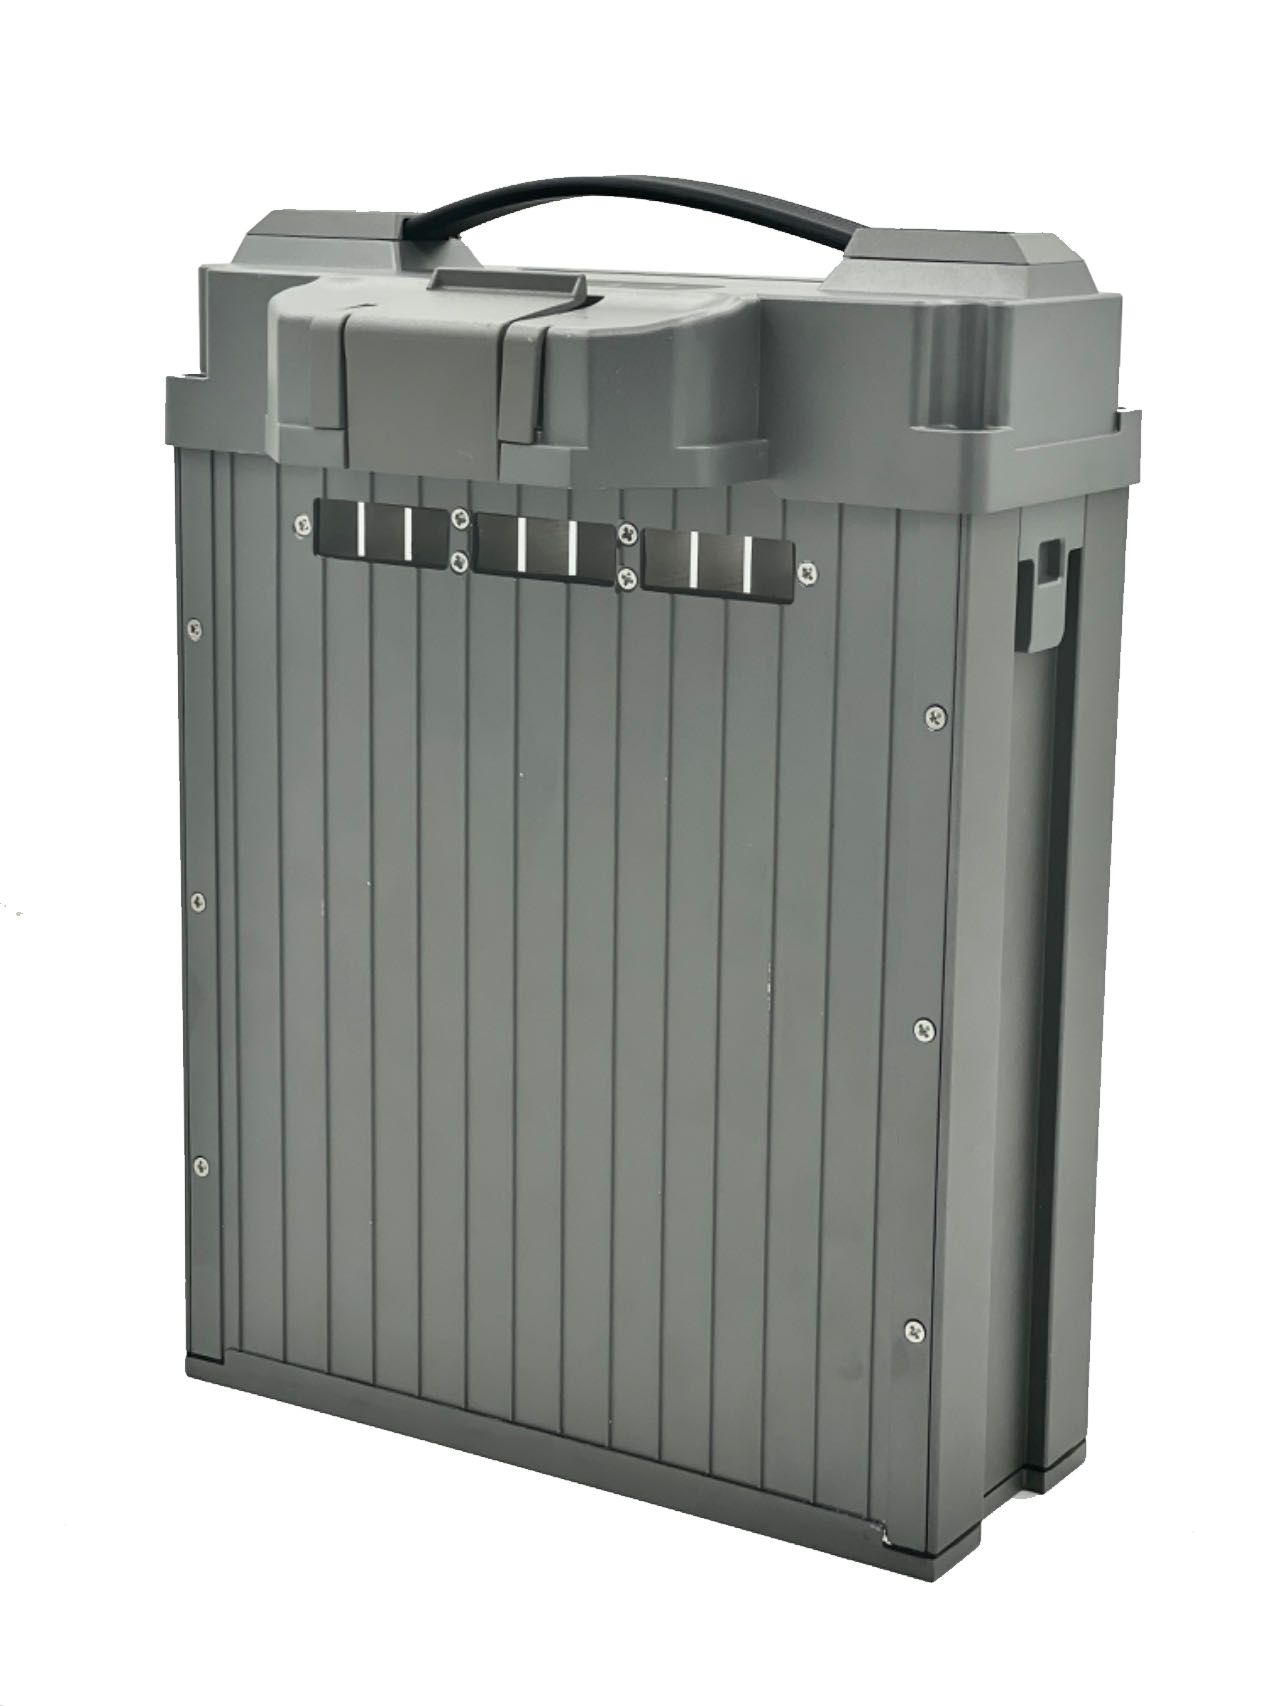
A 13–15 inch FPV platform changes the battery selection problem. It can carry more payload and a larger pack than a typical 5-inch build, so the battery can become a significant part of the mass budget while current demand exceeds what many hobbyist-market packs are designed to sustain. That is why a capacity label tells you so little here — and why a pack specified for a professional airframe has to be defined, not bought off a shelf.
This guide is about the values behind that label, written for the people who have to integrate the pack and sign it off: how much voltage the pack holds under load, how much current it can actually deliver, how much usable energy that leaves for the flight, and what pack mass the aircraft can carry without giving up the flight time you need. Each of these is a design decision with an owner — something you can specify, measure, and hold a supplier to.
Start with the system inputs that define what the battery actually needs to deliver:
Propulsion system sets the voltage and current envelope — motor KV, propeller size, and ESC rating together determine the current and headspeed range the battery must support.
Chemistry determines the power/endurance trade-off — where the pack sits between burst capability and energy per kilogram.
Internal resistance affects voltage stability under load — how much the bus voltage moves when the motors demand current.
Battery mass changes aircraft power demand — the pack is part of the mass the aircraft has to lift, so it feeds back into its own requirement.
Mission requirements determine the usable energy — the duty cycle decides how much of the nominal energy you can plan around.
Available space and fit set the physical boundary — bay dimensions, lead routing, and centre-of-gravity limits constrain which pack you can install.
Change any one of these and the others shift with it. That interdependence is why capacity alone is a poor definition variable, and why the process should start from the aircraft system rather than from mAh. The mission sets the requirements; the battery specification — chemistry, resistance, capacity, mass, and construction — decides how they are met. That is the difference between writing a battery spec and placing a battery order.
What Should You Consider When Selecting a 13–15 Inch FPV Battery?
Start with the aircraft, not the pack. Each input below is something you can obtain from your airframe, your motor supplier, or an existing flight log before you talk to a battery supplier.
Aircraft weight and payload
Establish the dry airframe mass first, then add payload, then add the battery mass you are considering. This third term gets underestimated, because it changes the answer you are trying to compute. In hover, the dominant aerodynamic requirement is generating enough thrust to support all-up weight; airframe drag becomes more relevant once the aircraft is translating through the air.
Keep three mass figures separate and documented: dry weight, mission payload, and battery mass. Their sum is your all-up weight (AUW), and every subsequent calculation depends on it.
Average and peak power demand
Once you know AUW and the propulsion set, you need two current figures, not one. The average figure covers hover and cruise and drives your capacity decision. The peak figure covers takeoff, climb, aggressive attitude recovery, and gust rejection — it sets whether the pack survives the mission at all.
Grab both from the motor thrust tables at your intended pack voltage, then confirm them against a flight log if the platform has flown. On most 13–15 inch platforms the gap between peak and average is wide enough that a pack sized only for average demand will sag hard during transients — and that sag can push the measured bus voltage toward an ESC or flight-controller low-voltage threshold while the pack still shows reasonable remaining charge.
Voltage platform
Voltage is not a preference; it is constrained by the ESC’s voltage rating, motor KV and propeller selection, the target operating point, and the current the rest of the power path can carry. A lower-KV motor on a higher-voltage pack produces a similar headspeed at lower current — the entire argument for moving up in cell count. Treat the ESC voltage ceiling as a hard constraint, not a target to approach. Running a 6S-rated ESC on 8S is not a tuning problem.
Target flight time
Define the flight time your mission actually requires, not the maximum the platform can reach. Inspection, mapping, and cinematic missions have very different duty cycles, and an endurance target set by “what is the longest flight possible” tends to produce an overweight aircraft with degraded handling.
Battery mass and available space
The pack has to fit, and it has to fit without moving the centre of gravity somewhere the flight controller cannot comfortably compensate. Measure the bay: length, width, height, and the direction the leads can exit. A pack that forces the main leads through a tight bend adds contact stress, and cable routing that lengthens the run adds resistance you will pay for in voltage sag.
6S vs 8S for a 13–15 Inch FPV Drone
The comparison between 6S and 8S is often framed as a power upgrade. From the battery and power-path perspective, the more direct effect is lower current for the same power demand — and almost everything else follows from that.
How voltage affects current: 6S vs 8S FPV battery
At a fixed power demand, current is inversely proportional to voltage: I = P / U. For illustration, assume a 1,000 W electrical demand. This is a calculation example, not a representative power rating for every 13–15 inch aircraft:
Platform | Nominal voltage | Fully charged | Current at 1,000 W | Relative current |
|---|---|---|---|---|
6S | 22.2 V | 25.2 V | ≈ 45.0 A | 1.33× |
8S | 29.6 V | 33.6 V | ≈ 33.8 A | 1.00× |
The 8S nominal voltage of 29.6 V and fully charged 33.6 V are standard for this configuration, as documented in independent 6S versus 8S battery references. The current comparison uses nominal voltage, not fully charged voltage, because nominal voltage is the more useful basis for comparing system-level power demand across battery configurations. The ratio between the two platforms is 29.6 / 22.2 = 1.333, so the 6S platform draws about 33% more current for the same electrical power demand. Note that this is the power drawn at the battery terminals, not the power delivered to the motors — the difference between the two is exactly the resistive loss discussed below.
Voltage drop and resistive losses
That 33% current difference matters far more than it appears, because every resistive loss term in the power path scales with the square of current.
Assume an example loop resistance of 0.05 Ω across connectors, wire, and pack, still at the same 1,000 W demand:
Quantity | Formula | 6S | 8S |
|---|---|---|---|
Resistive voltage drop | ΔV = I × R | ≈ 2.25 V | ≈ 1.69 V |
Conduction loss | P_loss = I² × R | ≈ 101 W | ≈ 57 W |
Heat over one minute | Q = I²Rt | ≈ 6,075 J | ≈ 3,428 J |
The 6S arrangement converts roughly 101 W into heat that never reaches the motors, and it holds a loaded bus voltage about 0.56 V lower at the same demand.
That gap tends to widen on its own. Hold the same thrust and the lower bus voltage pulls more current, which adds more loss; the extra heat then raises internal resistance, which adds more sag. It’s a feedback loop, and its entry point is the current that follows from your voltage choice.
The practical cost shows up over a long, high-power flight: accumulated heat pushes the ESC toward thermal derating, ages wire insulation and connectors, and can trip battery thermal protection mid-mission. None of it appears on a bench spec, and all of it surfaces under exactly the long-duration, high-load conditions a 13–15 inch platform is built for.
What changes when moving from 6S to 8S
Moving up a voltage step does not simply scale the aircraft. The pack, wiring, and connector all carry less current for the same power, so a given interconnect resistance costs you less. Lower current can also reduce the required conductor cross-section for a given voltage-drop target — though the actual cable spec still depends on current, length, temperature, and safety requirements.
Motor selection changes too. As a first-order approximation, keeping a similar propeller RPM at the higher voltage requires a proportionally lower motor KV. Reusing 6S motors on 8S raises headspeed and thermal load on both the motor and the ESC.
Voltage sag also falls — provided the comparison is made on an equivalent-resistance basis. With less current through the same resistance, ΔV = I × R produces a smaller drop. This does not mean an 8S pack is inherently lower in DCIR than a 6S pack. And consistency demands rise with cell count: more cells in series contribute to the pack voltage, so matching and monitoring matter more because a weak cell can limit the whole string. Finally, two extra series cells consume volume and, depending on cell format, mass — confirm the bay before committing.
Why 8S is not automatically better
An 8S platform is the stronger choice when the aircraft is heavy, the mission involves sustained high power, and the propulsion system is designed around the higher voltage from the start. None of those conditions is guaranteed by the cell count alone.
8S is the weaker choice, or an invalid one, when any of the following applies:
The ESC is rated for 6S. This is a hard electrical limit, not a margin you can tune around.
The motors were selected and validated only for 6S. Running the same motor at 8S changes its electrical operating point and can push RPM, current, and thermal load beyond the intended design envelope, which reduces rather than improves efficiency.
The mission is steady low-power cruise. At modest current demand, the I²R advantage shrinks toward irrelevance, and what remains is a heavier, more expensive pack with a greater cell-consistency burden.
The pack bay cannot accommodate the extra series cell without compromising leads routing or centre of gravity.
The supplier cannot demonstrate per-cell resistance consistency at 8S. A weak or high-resistance cell can limit the performance of the whole series string, so consistency evidence matters more, not less, at higher cell counts.
This is the same logic that applies across battery definition generally: the mission-profile-first selection logic starts from what the aircraft actually does, and the voltage step is a consequence of that, not a starting assumption. Read the correct way, the cell count is never the decision — it is one of its outputs.
LiPo vs Li-ion for 13–15 Inch FPV Applications
For the use cases covered in this guide, two cell categories are the main practical comparison: high-rate LiPo pouch cells and cylindrical Li-ion cells. There is no overall winner between them — they simply relax different constraints, which is why the LiPo vs Li-ion decision cannot be made independently of the voltage platform and the mission.
Peak and continuous discharge: LiPo vs Li-ion FPV battery
High-rate LiPo cells are generally designed for higher continuous and peak current than energy-oriented cylindrical Li-ion cells, with lower voltage sag across the range. Cylindrical Li-ion cells are built for energy rather than peak power: their continuous capability is a fraction of a comparable LiPo pack’s, and their per-cell resistance is substantially higher.
That resistance difference is the direct cause of the sag difference. Under the same absolute current, a higher-resistance Li-ion configuration will generally show more voltage sag than a high-rate LiPo configuration. The actual difference depends strongly on cell model, parallel count, temperature, state of charge, and pulse duration, so a single “volts of sag per cell” figure is not a useful procurement specification. The operational consequence is still real — a larger loaded-voltage drop is what changes how early the flight controller warns and when the ESC begins limiting — but the magnitude is a property of the specific pack, not of the chemistry label.
If your mission includes aggressive climbs, rapid altitude changes, or significant gust rejection, sag becomes the dimension you have to design around. Cylindrical Li-ion packs can still serve these missions, but they need careful pack sizing — typically more cells in parallel to split the peak current and hold the loaded voltage up. The chemistry doesn’t rule the mission out; the pack architecture decides whether it works.
Energy density and pack weight
Energy density is where Li-ion holds the advantage, but the margin depends entirely on whether the comparison is made at cell level or pack level.
Comparison level | LiPo | Cylindrical Li-ion |
|---|---|---|
Bare cell | Comparable in many constructions | Comparable in many constructions |
Finished pack | Varies widely by cell selection and pack design | Varies widely by cell selection and pack design |
At the cell level, energy-oriented cylindrical Li-ion cells can exceed many high-rate LiPo cells in specific energy. At the finished-pack level the gap becomes smaller and depends heavily on pack architecture: cylindrical cells may need steel casings, holders, and extra interconnects that add mass storing no energy, while pouch cells can achieve high pack-level utilization with a relatively light, compact enclosure. That is why cell-level energy density flatters cylindrical cells and why the finished-pack number is the only one worth comparing.
For industrial UAV packs, published pack-level claims should always be checked against the complete pack configuration and test basis.
One point is easy to miss: a lighter pack does not just reduce mass, it reduces the power the aircraft needs to hover. In an idealized hover model, hover power rises faster than the weight it has to lift, so a mass reduction compounds into an endurance gain larger than the mass fraction alone would suggest.
Cycle life
Li-ion cylindrical cells generally offer longer cycle life than LiPo pouch cells under comparable depth-of-discharge conditions. The practical consequence is not the cycle number itself but the service model: longer cycle life can reduce replacement frequency and potentially lower lifecycle cost, and it slows how often you must validate new batches.
Two caveats matter for specification. Cycle life is only meaningful with test conditions attached — depth of discharge, discharge rate, temperature, and the end-of-life threshold used to define the count — and a figure obtained at low discharge rates does not transfer to a high-current FPV duty cycle. Ask for the conditions explicitly, and expect the figure to shorten under real mission loading.
Matching chemistry to mission profile
Mission pattern | Voltage platform | Chemistry direction | Why |
|---|---|---|---|
Long-range cruise with occasional dynamic flying | 6S or 8S | Compare Li-ion and high-rate LiPo | Energy density matters during cruise, while peak-current capability must still cover the dynamic segments |
Sustained hover inspection, mapping passes | 6S or 8S | Cylindrical Li-ion | Current demand is steady and moderate; energy per kilogram and cycle life dominate |
Heavy payload with high gust exposure | 8S | High-rate LiPo | Peak current and sag resistance are the binding constraints |
Existing 6S, cost-sensitive light-duty operation | 6S | High-rate LiPo or existing validated pack architecture | Avoids changing the propulsion system when the current system already meets the mission requirements |
Whichever row matches your mission, treat the chemistry column as a starting direction rather than a finished answer. Chemistry sets the shape of the performance envelope; the voltage platform and the pack’s resistance determine how much of that envelope the aircraft can actually use.
Why Battery Internal Resistance Matters
A pack’s internal resistance is one of the most useful predictors of how it will behave under load, and it is the parameter least often specified properly. It sets voltage sag and heat generation, and in a series string the cell with the poorest voltage response under load can become the limiting cell for the pack. In a sustained high-power application, one high-resistance cell drags the whole string: it widens the per-cell voltage spread under load, pulls the pack’s effective capacity down ahead of the weaker cell, and accelerates cycle-life loss for the pack as a whole. Any serious FPV battery selection exercise reduces to this quantity sooner or later.
Understanding DCIR
Direct current internal resistance (DCIR) is an internal-resistance value derived from the voltage response to a defined DC current pulse or load step. Because it is measured rather than fixed, the value shifts with pulse duration, state of charge, temperature, and test procedure — so it should always be specified together with its test conditions. Higher internal resistance causes more voltage sag and more heat under load. For a high-power FPV platform, that means the available voltage can drop before the battery has actually reached its nominal empty state — the aircraft may see a low-voltage condition while usable charge still remains.
For procurement purposes, two facts matter more than the definition. A 1 kHz AC resistance measurement and a DC pulse test measure different behavior, so their values aren’t interchangeable — and the number you get depends on how it was measured. Research published in Scientific Reports on how measurement timescale shapes internal resistance characterization shows the value shifts with pulse duration, which is why a pack that looks healthy on an ACIR meter can still sag in flight. Any resistance figure you receive should come with its measurement method attached.
Per-cell DCIR varies widely by cell construction, capacity class, temperature, state of charge, cycle history, and — critically — the measurement procedure used to obtain it. The values below are examples from specific published cell measurements, not generic specifications you should assume for any cell class:
Cell example | Reported DCIR under the cited test conditions |
|---|---|
21700 cylindrical Li-ion | ~13 mΩ |
18650 cylindrical Li-ion | ~25 mΩ |
These values are examples from specific cells and test conditions, not generic specifications for all 21700 or 18650 cells. The gap between the two formats in the cited comparison is structural, not a quality difference. A direct 18650 versus 21700 resistance comparison published in the Journal of Power Sources measured DC internal resistance at roughly 25.0 mΩ for the 18650 and 13.2 mΩ for the 21700 under matched conditions — the larger format’s electrode area and shorter current path account for the difference.
How internal resistance creates voltage sag
Voltage sag is the drop from a lightly loaded voltage to the loaded terminal voltage during a high current demand. In practical terms:
ΔV ≈ (I × R internal) + polarization effects
The resistive part recovers the instant current falls; the polarization part does not, and clears over seconds to minutes. That asymmetry is the practical reason a pack can pass a short bench pulse test and still collapse during a sustained climb. For integration, the takeaway is simple: accept a battery on a dynamic, real-mission discharge profile across state of charge and temperature, not on a single static discharge curve.
Assume an 8S1P string (one cell per series group) using cells with a measured DCIR of 13 mΩ per cell under the same defined test condition. The cell contribution alone is 8 × 13 = 104 mΩ before any interconnect or connector resistance. At a 60 A sustained draw, the purely resistive component would be about 6.2 V, before accounting for temperature, polarization, state of charge, and the rest of the pack resistance. That does not mean every 21700 pack will lose 6.2 V in flight — the example shows why an energy-oriented cell with a given measured resistance may be unsuitable for a 60 A series-string duty cycle unless parallelization and operating conditions are designed around it. This drop comes from cell selection rather than from wiring, so heavier cable will not fix it. It is the arithmetic behind why energy-optimized cells suit cruise missions and high-rate cells suit dynamic ones.
Pack configuration and cell matching
Series and parallel connections do different jobs, and both have procurement consequences.
Series raises voltage. Resistance accumulates along the string, so a 6S string carries six times the per-cell value, and more cells in series means more that can contribute to pack-level imbalance — so matching and monitoring matter more.
Parallel raises capacity and lowers the pack’s equivalent resistance, since parallel paths divide the load. That improves load capability — but adding parallel cells reduces current per cell while also adding mass, volume, and interconnects, feeding straight back into aircraft power demand. And parallel groups need matched cells. Where cells in the same parallel group are mismatched — mixing new and aged cells, or combining groups without design — the weaker cell can be driven into a circulating current by its higher-resistance neighbour, which adds a hidden loss and extra sag on top of the normal load current. Research on internal resistance matching in parallel-connected cell groups in the Journal of Power Sources found that greater resistance mismatch shortens pack lifetime, because the lower-resistance cell carries more current and ages faster. The study used LiFePO4 cells, so its figures do not transfer to other chemistries — but the conclusion does.
The practical rule for a specification: never accept mixed new and aged cells in the same parallel group, and ask for per-cell resistance data with a stated measurement method rather than a pack-level figure alone.
Connectors, welds, and interconnect resistance
For most packs, a useful first-order resistance model is that the cells are only one part of the budget:
R pack ≈ Σ R cells + R interconnects + R leads + R connector
In high-current builds, the non-cell terms are frequently the difference between a pack that performs as specified and one that does not. Interconnect material and thickness, weld quality and coverage, wire gauge, cable length, and connector condition all contribute. Long lead runs, thin nickel, partial or cold welds, and oxidized connector contacts each add resistance that appears in the flight log as unexpected sag.
A practical first-pass diagnostic sequence is to inspect the connector and cable path before assuming the cells are the problem. That outside-in approach is documented in a walkthrough of FPV voltage sag traced from connectors through cable gauge to pack resistance, and it is a sensible order to try on a 13–15 inch platform as well.
Once you have the measurements, match the symptom to the most likely source before you start swapping parts.
Observed symptom | Likely dominant source | What to check first |
|---|---|---|
Sag present from the first flight on a new pack | Cell DCIR or interconnect resistance | Per-cell resistance data and weld quality |
Sag worsening gradually across many cycles | Rising cell DCIR with age | Per-cell resistance trend versus baseline |
Sag concentrated in one cell of the string | Cell consistency failure | Per-cell voltage spread under load |
Sag worse after a cable or connector change | Interconnect or contact resistance | Connector contacts, wire gauge, cable length |
Sag worse when the pack is cold | Temperature-driven resistance rise | Operating temperature versus specification |
Large sag only at the start of high-current bursts | Polarization component | Sustained-load test rather than short pulse |
Why a Larger Battery Does Not Always Mean Longer Flight Time
The intuitive model — more capacity, proportionally more flight time — breaks down on this platform class for a specific reason: the battery is part of the mass the aircraft has to lift.
Battery mass changes aircraft power demand
For an idealized multirotor hover condition, induced power scales approximately with the 3/2 power of the required lift. Real aircraft power also depends on propeller efficiency, disk loading, motor efficiency, air density, and other losses. Add battery mass and you raise hover power at the same time you raise available energy. The two effects partially cancel.
Take an example assumption for a 13-inch platform, keeping all values illustrative. Assume the two packs have similar pack-level energy density and differ mainly in capacity and mass, so the heavier pack’s extra mass is what buys the extra energy:
Parameter | Modest pack | Larger pack |
|---|---|---|
Battery mass | 300 g | 450 g |
Aircraft mass excluding battery | 1,200 g | 1,200 g |
All-up weight | 1,500 g | 1,650 g |
Steady cruise power demand | 550 W | 620 W |
Nominal pack energy | 22.2 V × 5.0 Ah = 111 Wh | 22.2 V × 8.0 Ah = 178 Wh |
Endurance at 85% usable energy | 111 × 0.85 / 550 × 60 ≈ 10.3 min | 178 × 0.85 / 620 × 60 ≈ 14.6 min |
The 85% figure here is an illustrative placeholder for the calculation, not a universal safety standard. Real usable energy depends on your cutoff policy, the loaded voltage the aircraft flies at, cell temperature, and the age of the pack — treat the result as a relative comparison between two packs, not an absolute flight-time prediction.
Adding battery capacity changes both sides of the endurance equation: it adds stored energy, but it also adds mass the aircraft must continuously lift. Capacity rose 60%. Endurance rose about 42%, not 60%, because power demand rose 12.7% alongside it. Push further in the same direction and the gain flattens. For a given aircraft and propulsion system, there can be a point beyond which additional battery mass produces little endurance gain and can eventually reduce endurance, because the extra hover power consumes the extra energy entirely. The same arithmetic explains why an over-sized pack costs you agility and wind resistance as well, since the added mass reduces thrust-to-weight margin.
Capacity vs usable energy
Capacity in milliamp-hours is a charge quantity, not an energy quantity. It says nothing about voltage, so it cannot be compared across platforms and it cannot be converted into endurance without a voltage term.
Usable energy is what matters, and it is smaller than nominal energy for three reasons:
Discharge cutoff policy. Ending the flight at a conservative loaded voltage leaves energy in the pack. This is a safety decision, not waste.
Loaded versus nominal voltage. The voltage the aircraft actually operates at under load is below nominal, so delivered energy is lower than the nominal calculation suggests.
Temperature. Cold cells deliver less usable capacity and exhibit higher resistance, reducing both available energy and delivered voltage simultaneously.
The conversion is E = U nominal × C. A 6S 5,000 mAh pack is 22.2 × 5.0 = 111 Wh. An 8S 5,000 mAh pack is 29.6 × 5.0 = 148 Wh. The same milliamp-hour figure, two very different energy totals — which is the practical reason to stop planning in mAh.
A simple FPV battery flight-time calculation
You can turn that energy figure into a planning estimate in three steps, using nominal voltage throughout:
1. Nominal energy (Wh) = nominal voltage (V) × capacity (Ah)
2. Estimated flight time (min) ≈ usable energy (Wh) ÷ average electrical power (W) × 60
3. Apply the usable-energy fraction you plan with for your own operation.
Worked example, 6S 6,000 mAh: 22.2 × 6 = 133.2 Wh. With an average electrical demand of 700 W and a planning assumption of 85% usable energy, 133.2 × 0.85 ÷ 700 × 60 ≈ 9.7 minutes; at 90% usable energy the same inputs give approximately 10.2 minutes. Note that the calculation uses nominal voltage, not the 25.2 V fully charged figure, for the same reason the 6S/8S current comparison does. As above, the 85% figure is an illustrative planning assumption, not a default safety standard — substitute the usable-energy fraction your own cutoff policy and operating conditions justify.
This is a planning estimate, not a guaranteed flight time, and real flights rarely reach the pure arithmetic figure. Four factors account for most of the gap.
Flight attitude: a steady cruise draws the least power, while fast climbs, high-speed forward flight, attitude corrections, and gust rejection can push instantaneous demand past 1,000–1,200 W.
Environment: headwinds and crosswinds add thrust demand, while high altitude and cold air raise cell resistance and cut usable capacity at the same time.
Voltage decay: as the pack discharges, the bus voltage falls, so holding the same thrust takes more current and raises late-flight average power.
Onboard equipment: gimbal, camera, video transmitter, GPS, and telemetry all draw continuously on top of propulsion.
For mission planning, usable energy is still not the energy you should budget — a reserve must remain for return-to-home, landing, or unexpected demand. Because that reserve depends on return distance, wind, battery age, and flight-controller configuration, set it from your own operation rather than a general percentage.
The same gap appears in in-flight charge estimation. A voltage-based estimate reads loaded terminal voltage rather than open-circuit voltage, so it drifts under high current and can trigger early low-battery warnings even when usable energy remains. Treat the warning as a signal to verify, not a precise fuel gauge.
Pack-level energy density
Whichever cell class you choose, the figure that determines your mass budget is pack-level energy density, not cell-level. As covered above, a finished cylindrical pack carries casing, holder, and interconnect mass that stores no energy, so a cell-level number flatters it. For an integration decision, compare packs at the pack level and with a stated test basis, and treat an out-of-band claim as a question to put to the supplier rather than a given.
Defining the Pack, Not Shopping for One
Step back from the individual comparisons, and the structure of the problem holds together. Voltage sets the electrical architecture, and therefore the current every other component has to carry. Chemistry sets where the pack sits on the power-versus-endurance trade-off, not a ranking between them. Internal resistance determines how stable the bus voltage stays under load, and therefore how much of the pack’s usable energy the aircraft can actually reach. Battery mass feeds back into hover power, so a bigger pack is never a straightforward energy addition. And the mission decides how much of the nominal energy is genuinely usable.
Reading a capacity label resolves none of those relationships, and neither does picking the highest cell count available. They are resolved by defining the pack against the aircraft it has to power. A usable battery specification, built from those relationships, looks like this:
Configuration: 8S (nominal 29.6 V)
Capacity: 8–12 Ah
Continuous current: ≥ XX A
Peak current: ≥ XX A for XX s
Mission duty cycle: XX min cruise / XX s climb / XX s peak
Pack-level energy: XX Wh
Target pack mass: ≤ XX g
DCIR: ≤ XX mΩ per cell / pack, measured at XX °C and XX% SOC using a defined pulse duration
Discharge temperature: XX–XX °C
Charge temperature: XX–XX °C
Connector: XT90 / AS150 / custom
Dimensions: L × W × H (with lead exit direction)
Cell matching tolerance: as specified by the supplier
Telemetry / monitoring: if applicable
What matters most here is not the exact numbers but that every line is a deliberate decision made against a known aircraft and mission. An 8S 10,000 mAh label is not a specification — it is a starting point that still leaves current, mass, resistance, and fit undefined. This is the difference between buying a battery and defining one.
If you need a practical place to begin the evaluation, these are directions rather than answers:
High dynamic flying or heavy payload → evaluate an 8S high-rate LiPo configuration first.
Long, steady cruise → evaluate cylindrical Li-ion first if your peak current stays within its tested envelope.
Existing 6S propulsion system → stay within the validated 6S system rather than changing voltage only to chase efficiency.
Mixed mission → compare both configurations against measured power logs before committing.
Treat each of these as a hypothesis to check against your own current and mass data, not a recommendation that overrides what the aircraft needs.
This definition work is also where your choice of supplier either removes uncertainty or adds to it. A manufacturer that publishes resistance data with its measurement method, matches cells within a pack, and supports the pack geometry your airframe actually needs helps you eliminate design risk before the first flight rather than after it appears. When you evaluate a battery partner, put those three things on the checklist first — they tell you more about real-world performance than any capacity number on a label.
 Nederlands
 English
 Español
 한국어
 Deutsch
 Français
 日本語
 Русский
 Bahasa Indonesia
 ไทย
 العربية
 Português do Brasil
 Italiano